Electrical Engineering · Autonomous Systems · Controls

Dante Benedetti

Electrical engineer focused on autonomous systems, controls, robotics, computer vision, and embedded systems.

I design and build intelligent electromechanical systems spanning real-time embedded control, state estimation, autonomous navigation, computer vision, and robotic manipulation.

Portrait of Dante Benedetti.

Engineering through design, experimentation, integration, and testing.

I am an Electrical Engineering student at California Polytechnic State University, San Luis Obispo, with a particular interest in controls, robotics, embedded systems, and autonomous machines.

My projects have included autonomous mobile robots, quadrotor flight control, computer vision, robotic manipulation, embedded motor control, renewable energy systems, and autonomous vehicle navigation. I enjoy working across the full engineering stack — from sensors, electronics, firmware, and control algorithms to system integration and physical testing.

Projects

A selection of projects involving autonomous systems, robotics, controls, embedded systems, computer vision, and electrical engineering.

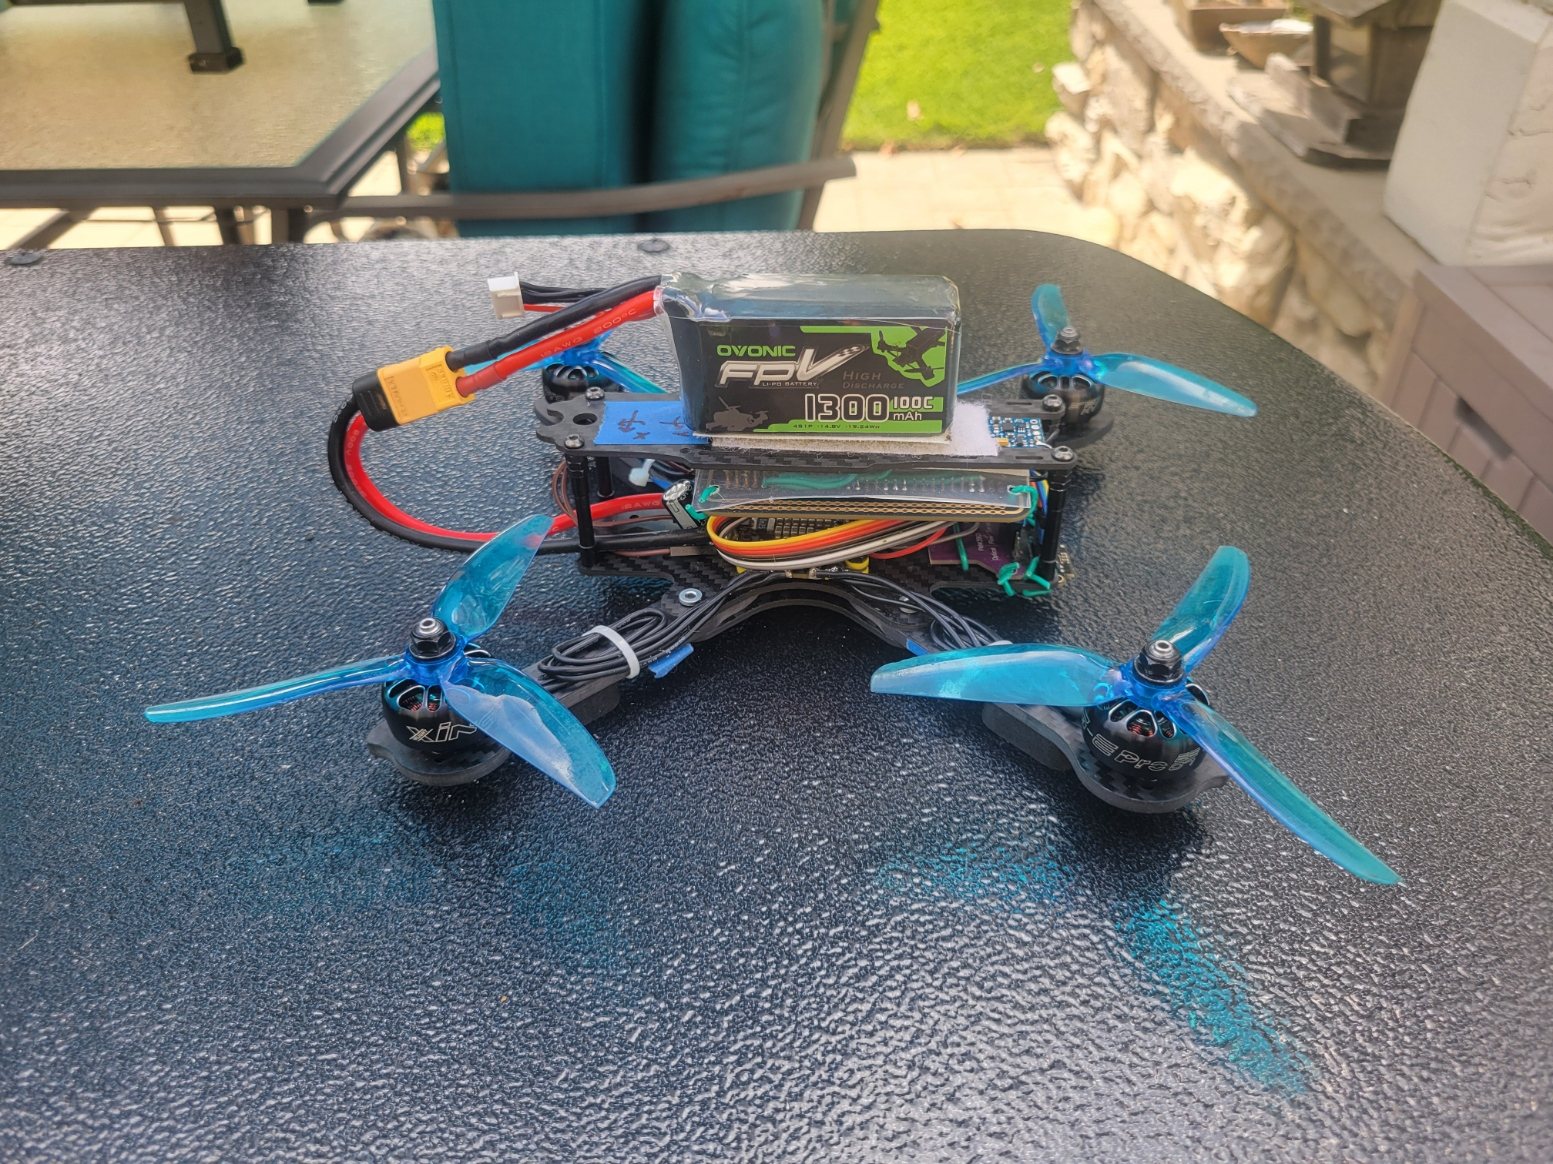
Side view of the custom 232 mm quadrotor showing its stacked deck layout, battery, and tri-blade propellers.

Flight Controls · Embedded Systems · State Estimation

Quadrotor Flight Controller

Designed and built a custom 232 mm quadrotor platform using 5-inch propellers and a sensor-fusion-based flight-control architecture.

Developed attitude and altitude control using PID feedback with IMU, magnetometer, optical-flow, and time-of-flight sensing, while implementing EKF-based state estimation for autonomous position control.

PID EKF IMU Optical Flow ToF Magnetometer
View Project →
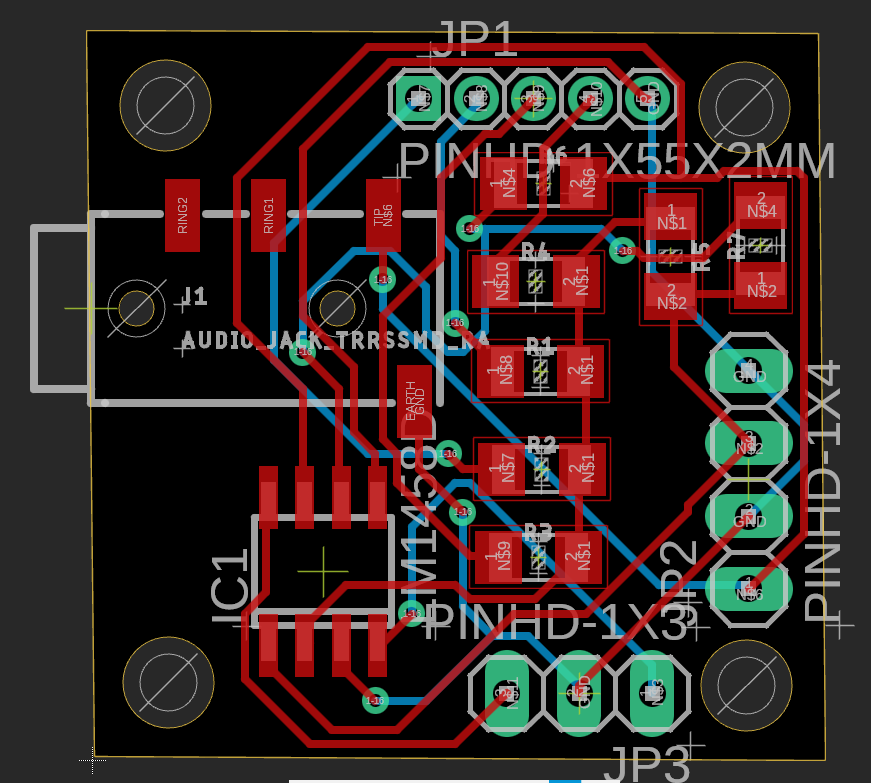
Two-layer PCB layout of a 4-bit DAC on a one-inch board, with red top-layer and blue bottom-layer traces.

PCB Design · Analog Electronics · Schematic Capture

4-Bit DAC on a One-Inch PCB

Designed a binary-weighted resistor DAC around an LM1458 dual op amp, simulated it in LTspice, then captured the schematic and laid out a 1″ × 1″ two-layer, all-surface-mount board in Fusion 360.

Built and tested stage by stage, then used to play digital audio from a laptop through a speaker via the on-board audio jack.

PCB Layout Fusion 360 LTspice Surface Mount Op-Amp Design
View Project →
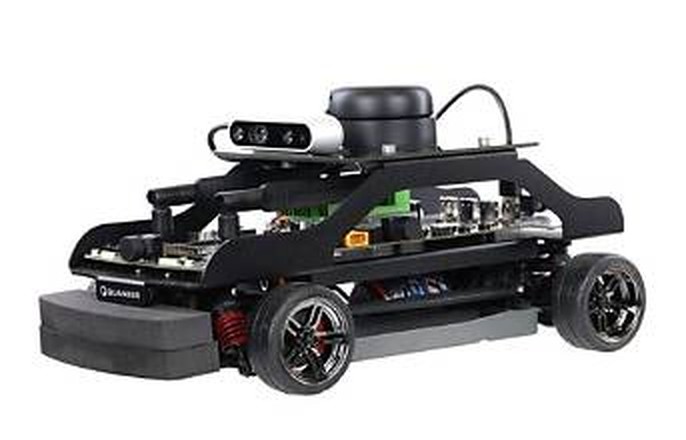
The Quanser QCar 2 autonomous vehicle platform.

Autonomous Vehicles · Computer Vision · Planning & Control

Perception-Aware Autonomous Vehicle

Developed an autonomous-driving stack for the Quanser QCar 2 capable of navigating a planned route while responding to stop signs and traffic lights.

Integrated global path planning, Stanley steering, PI speed control, RGB-D perception, traffic-sign detection, traffic-light classification, and finite-state-machine behavior in both simulation and physical testing.

Python OpenCV Stanley Control PI Control RGB-D FSM
View Project →
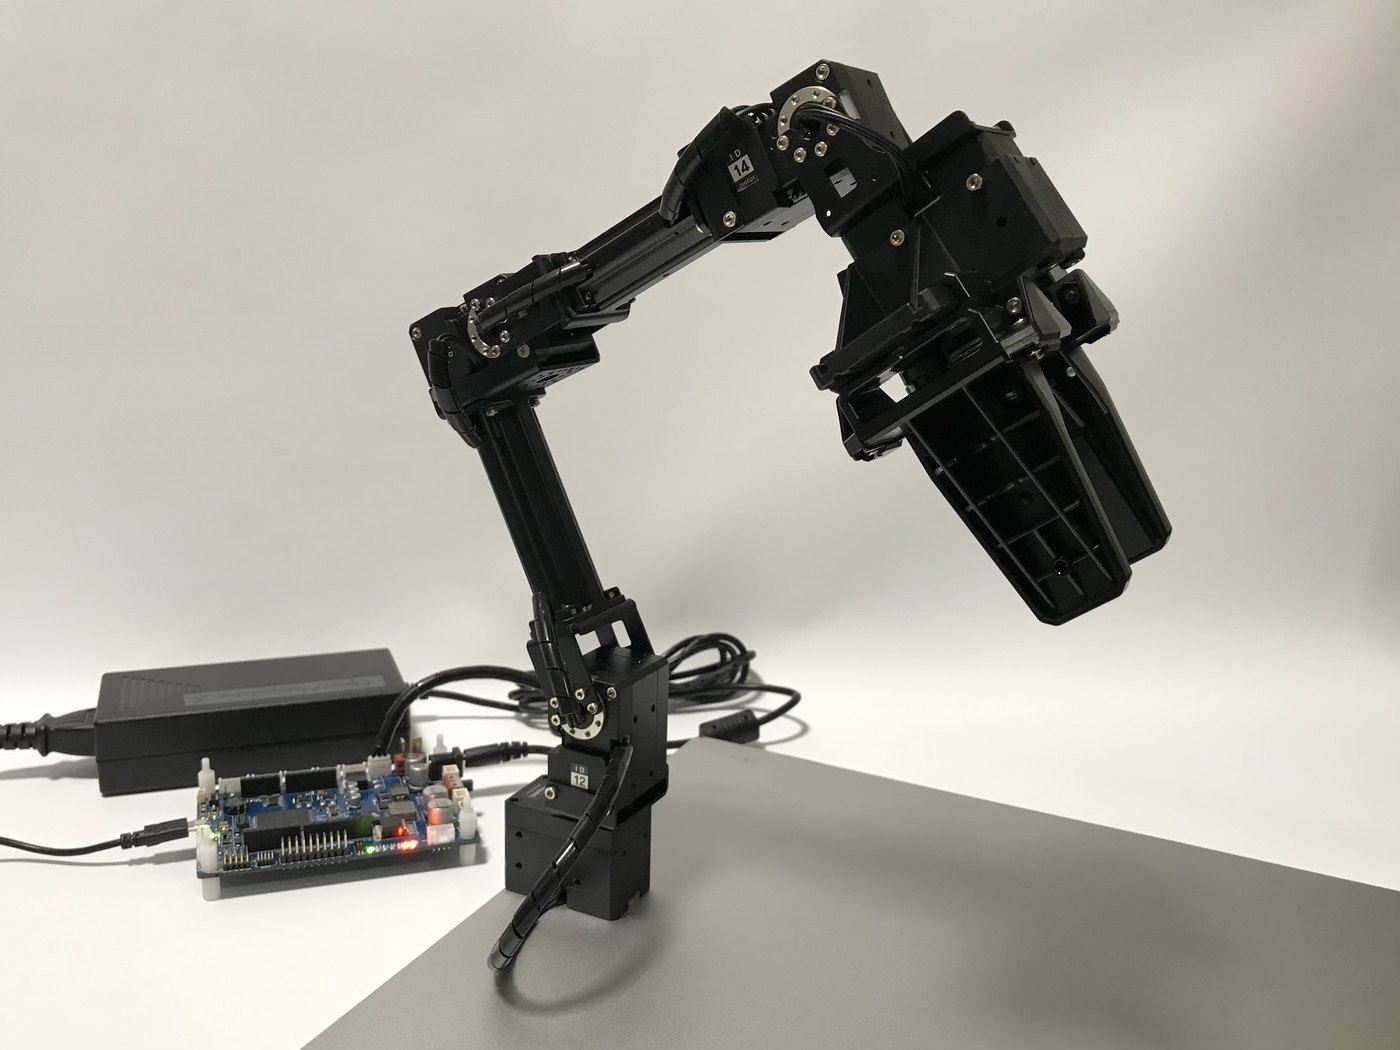
The OpenManipulator-X robotic arm with its OpenCR control board.

Robotics · Computer Vision · Python

Vision-Based Robotic Manipulator

Implemented image-processing and robotic-control algorithms for a four-joint robotic arm using object-oriented Python.

Developed trajectory-generation methods and evaluated forward and inverse kinematic models for autonomous manipulation tasks.

Python Computer Vision Forward Kinematics Inverse Kinematics
View Project →
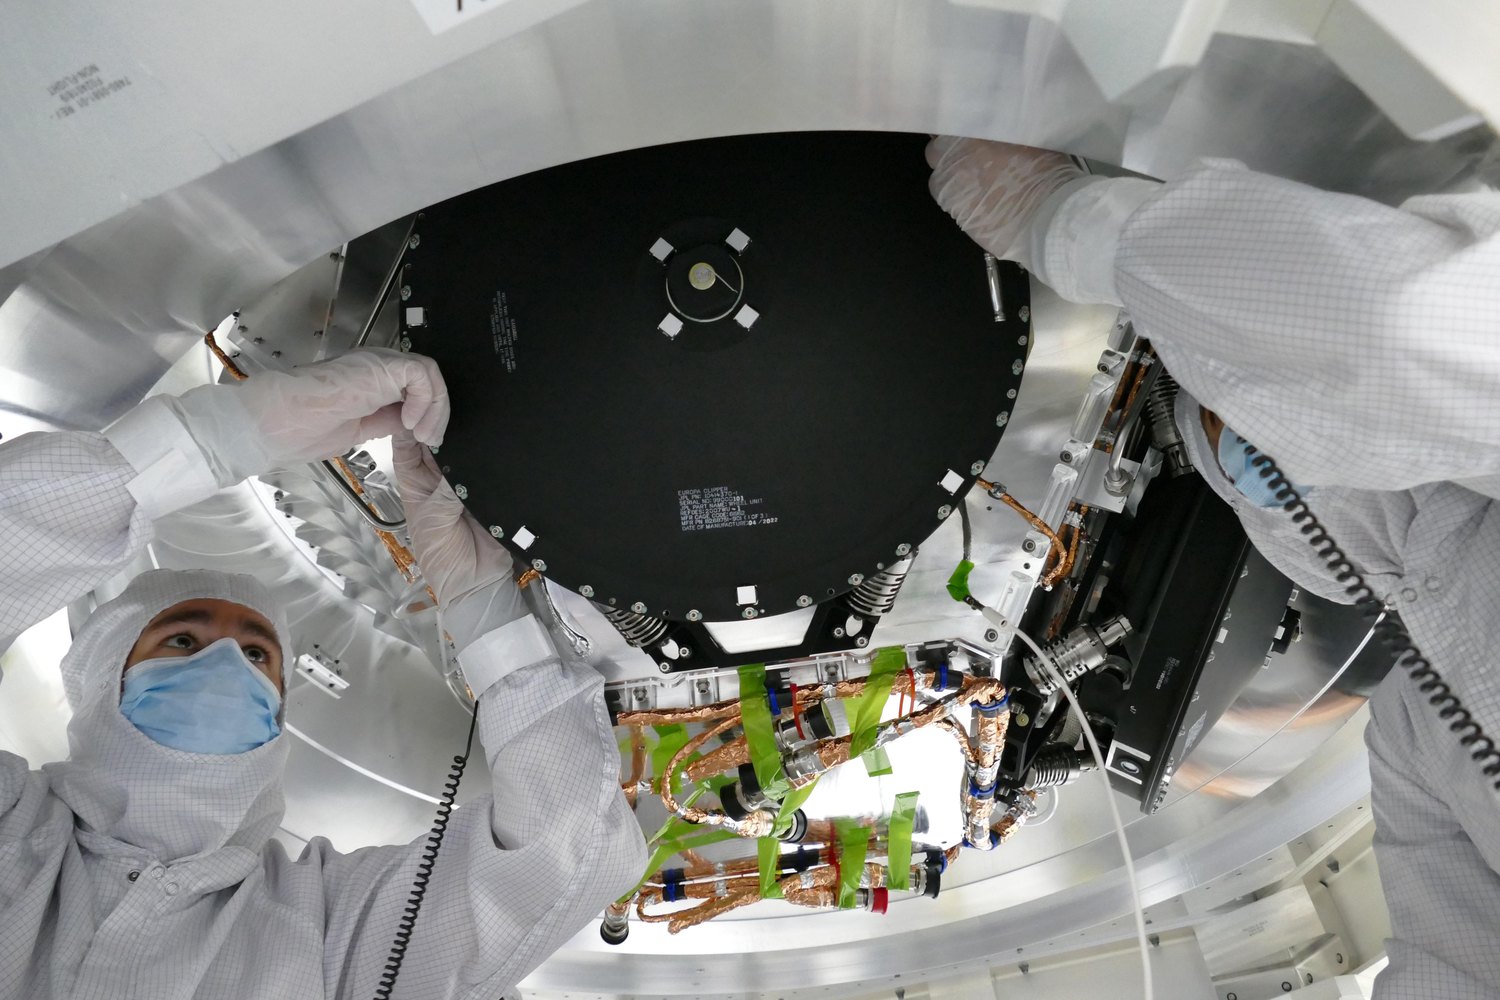
Technicians installing a reaction wheel on NASA's Europa Clipper spacecraft.

Modern Control · State-Space Design · Estimation

Reaction-Wheel Satellite Attitude Control

Derived a third-order state-space model for a single-axis satellite actuated by a reaction wheel and an external thruster, and showed from its Jordan structure why the open-loop system drifts without bound.

Designed a multi-input pole-placement controller with a reference prefilter for unity tracking, plus a full-order Luenberger observer that reconstructs the unmeasured satellite rate from attitude and wheel-speed telemetry.

State-Space Pole Placement Luenberger Observer Controllability MIMO MATLAB
View Project →
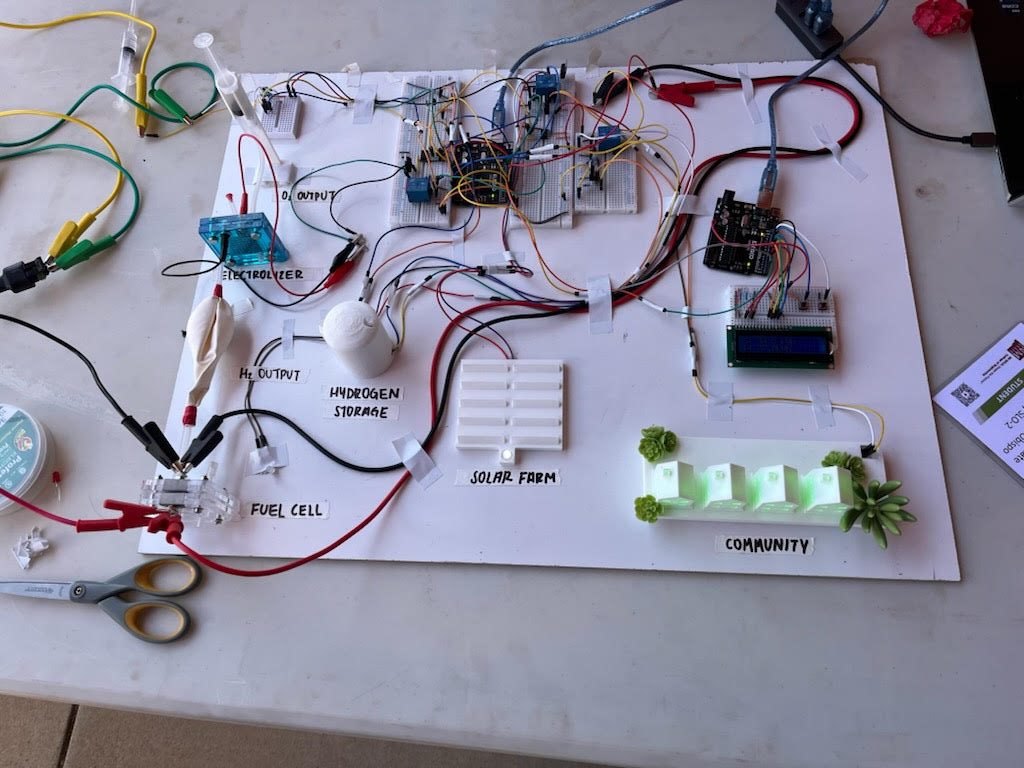
The bench-scale hydrogen demonstration board with electrolyzer, fuel cell, solar panel, Arduinos, and lit community LEDs.

Energy Systems · Research · Engineering Design

Green Hydrogen Grid Stabilization

Researched, designed, and evaluated a scalable green-hydrogen energy-storage system intended to improve electrical-grid stability.

Developed the project through multiple design iterations and presented the final system at the WERC Environmental Design Contest at New Mexico State University.

1st Place — WERC Environmental Design Contest, Task 2
IEEE Xplore Publication: Sustainable Grid Stabilization Via Green Hydrogen Technologies
View Project →
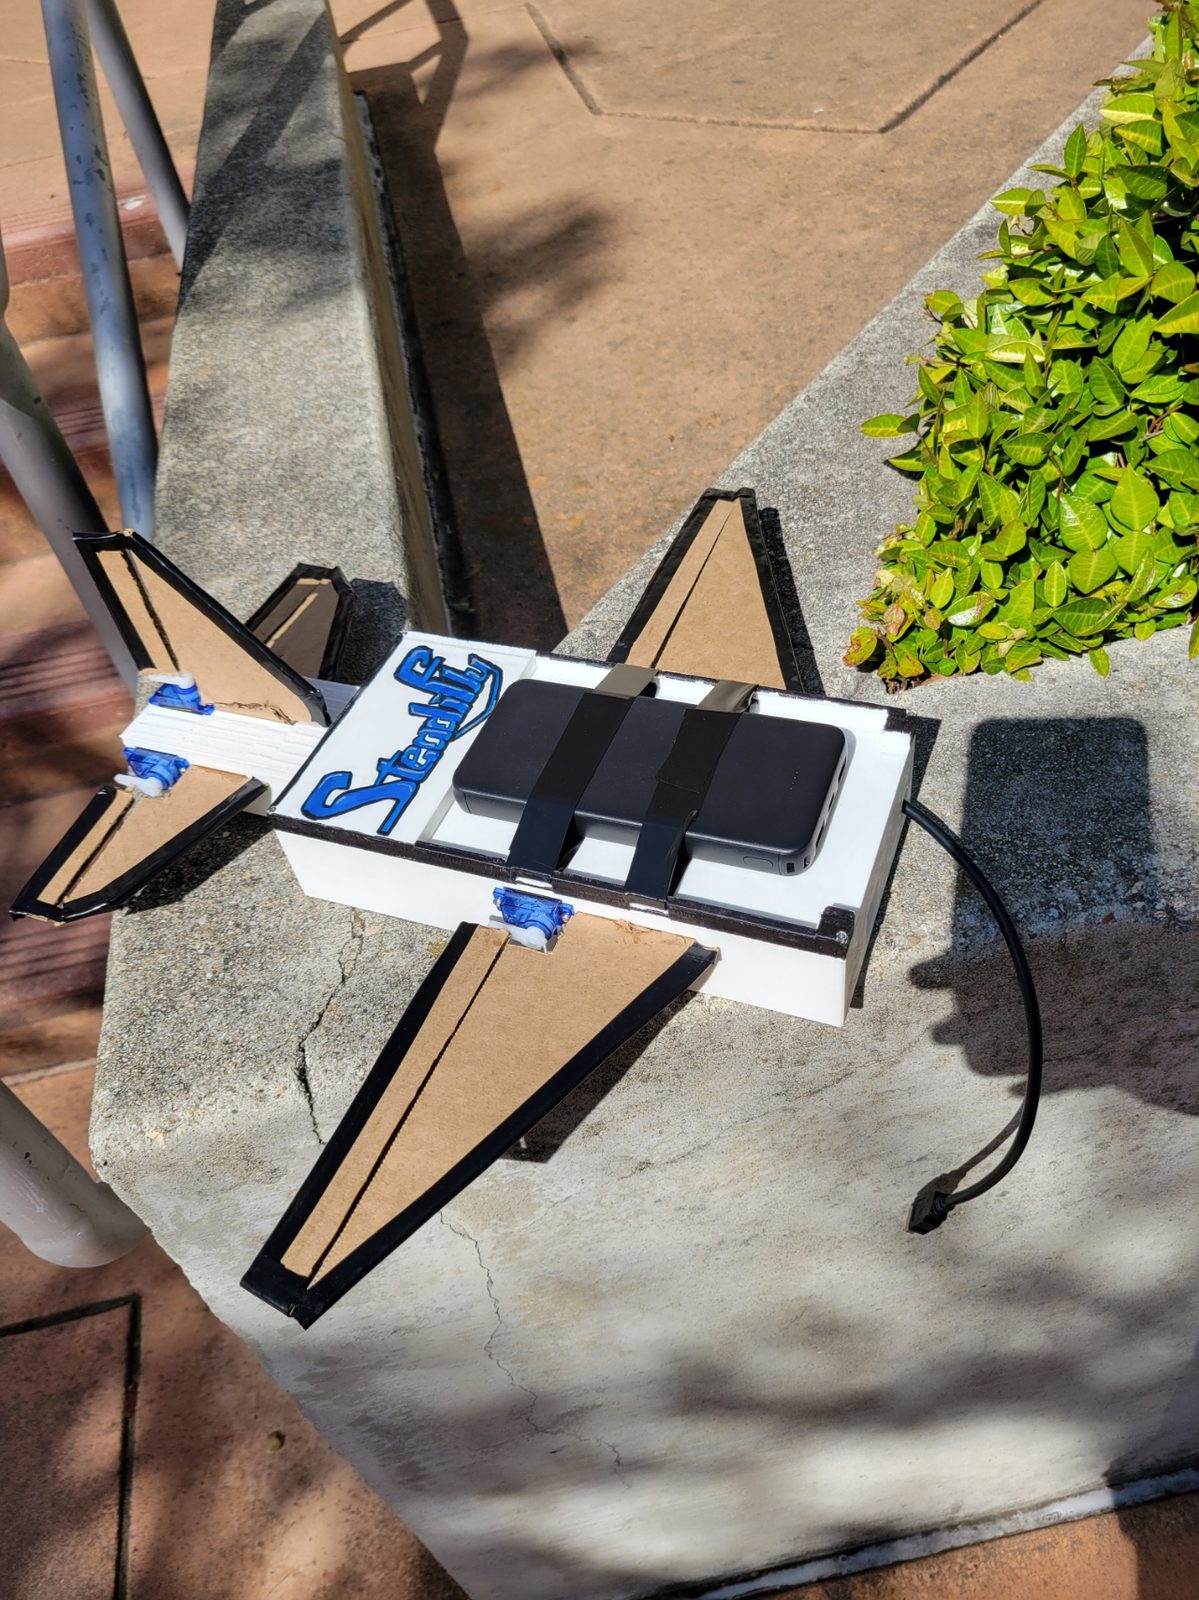
The SteadiFly airframe with servo-driven control surfaces and onboard battery.

Embedded Controls · STM32

3-Axis Flight Stabilizer

Developed and tested a three-axis embedded stabilization system using gyroscope and accelerometer feedback, five servo motors, and an STM32-based Nucleo platform.

Worked through system production, control development, testing, troubleshooting, and hardware integration.

STM32 IMU Servos Embedded Control
View Project →

California Polytechnic State University

San Luis Obispo, California

Incoming · Fall 2026

M.S. Electrical Engineering

College of Engineering

2022–2026

B.S. Electrical Engineering

GPA: 3.89

Dean's List

Selected Coursework

Controls & Autonomous Systems

  • Control Systems Theory
  • Classical Control Systems
  • Digital Control Systems
  • Planning & Control for Autonomous Vehicles

Robotics & Computer Vision

  • Computer Vision
  • Vision-Based Robotic Manipulation
  • Autonomous Vehicles Laboratory

Embedded & Digital Systems

  • MCU-Based System Design
  • Digital Design
  • Computer Design & Assembly Language
  • Data Structures

Electronics & Electromagnetics

  • Electronic Design
  • Analog Electronics & Integrated Circuits
  • Electric Circuit Analysis I–III
  • Electromagnetic Waves

Technical Skills

Programming & Embedded

Python · STM32 · CubeIDE · ROS 2 · Vivado

Controls & Robotics

PID · EKF · State Estimation · Path Planning · Computer Vision · Robotic Manipulation

Engineering Tools

Fusion 360 · LTspice · AutoCAD · Git

Laboratory

Oscilloscope · Function Generator · Digital Power Supply · Soldering

Engineering beyond the classroom.

Project Engineer

Pribuss Engineering Inc.

South San Francisco · June–September 2025

Designed multi-level fire-protection systems using AutoCAD and AutoSprink for projects requiring San Francisco city approval.

Coordinated field inspections, material deliveries, and hydraulic-design requirements while working across engineering, construction, and municipal approval processes.

Awards & Publication

2025

1st Place — WERC Environmental Design Contest

Task 2 Overall Design

IEEE Xplore

Sustainable Grid Stabilization Via Green Hydrogen Technologies

Research publication developed through the WERC Environmental Design project.

View on IEEE Xplore →

Let's connect.

I am interested in opportunities involving autonomous systems, robotics, controls, embedded systems, and electrical engineering.